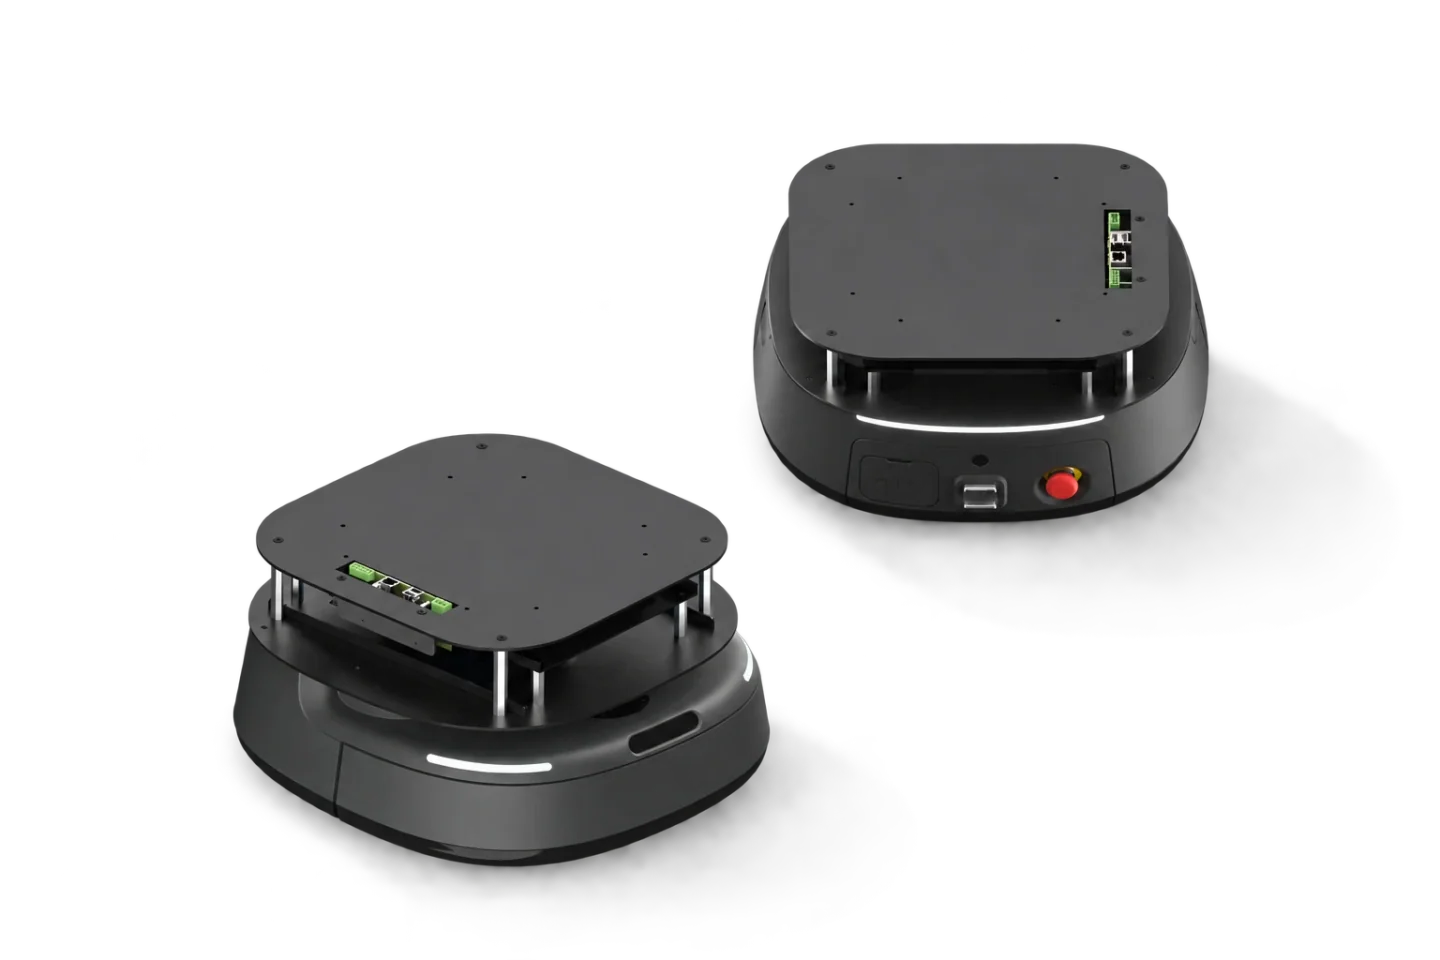
SR-C400
Home robot platform
400 × 400 × 260 mm
Payload 20 kg
SHINING ROBOTICS
Standard robot chassis and custom robot development. Connect your intelligence to the physical world through our mobility hardware, embedded systems and motion-control interfaces.
ACADEMIC PRICING · WORLDWIDE
For universities, labs, research groups and teaching teams worldwide. C400 / C500 / C600 / C800 / X700 are all eligible. Private quotations follow review.
No registration or proof upload required initially. We reply within 2 working days.
ROBOT PLATFORMS
ROS 1 / ROS 2 drivers and TCP/IP interfaces support your own or third-party robot intelligence. Choose motion, then confirm payload and integration space.
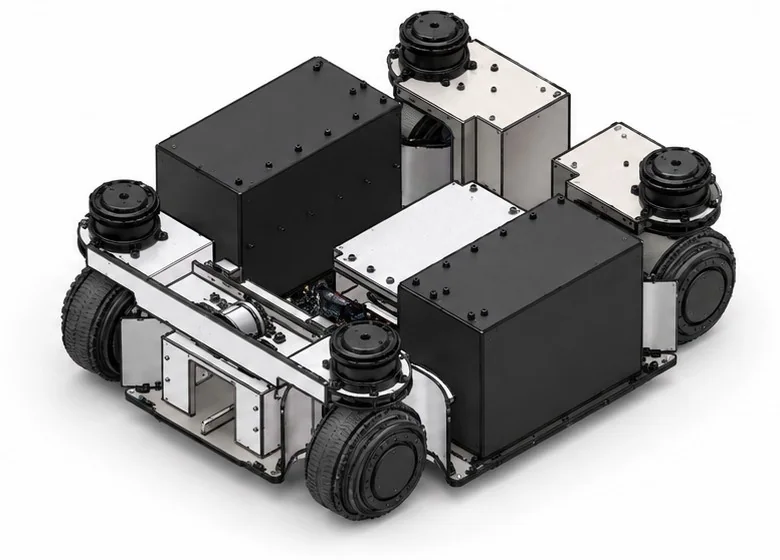
SR-X700 · 4WD / 4WS
Four-wheel steering and four-wheel drive provide a mobile foundation for upper modules and robot development.
Home robot platform
400 × 400 × 260 mm
Payload 20 kg
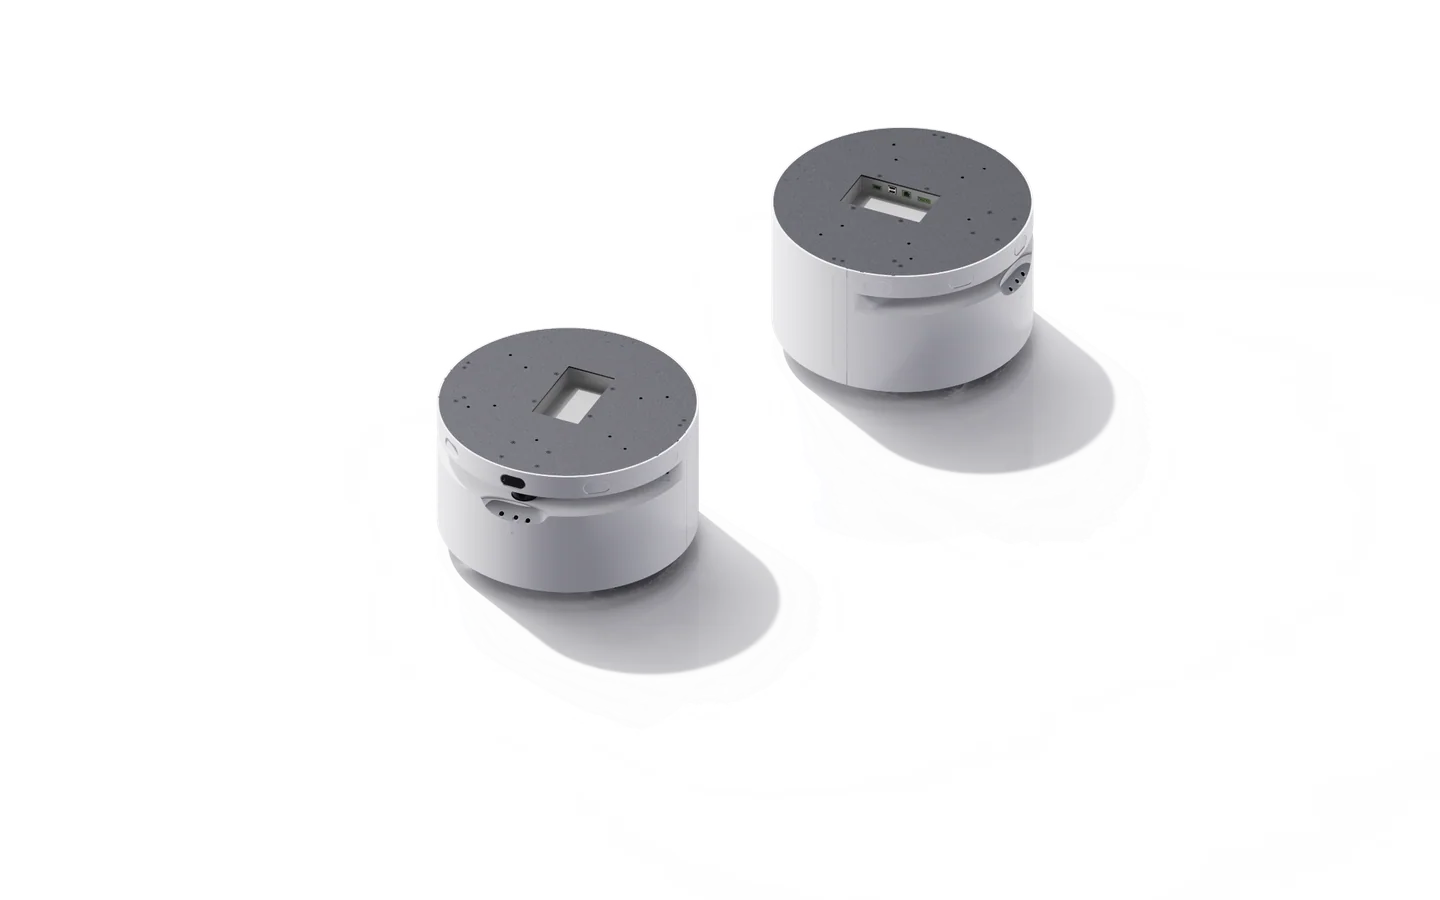
Compact differential-drive platform
500 × 500 × 310 mm
Payload 50 kg
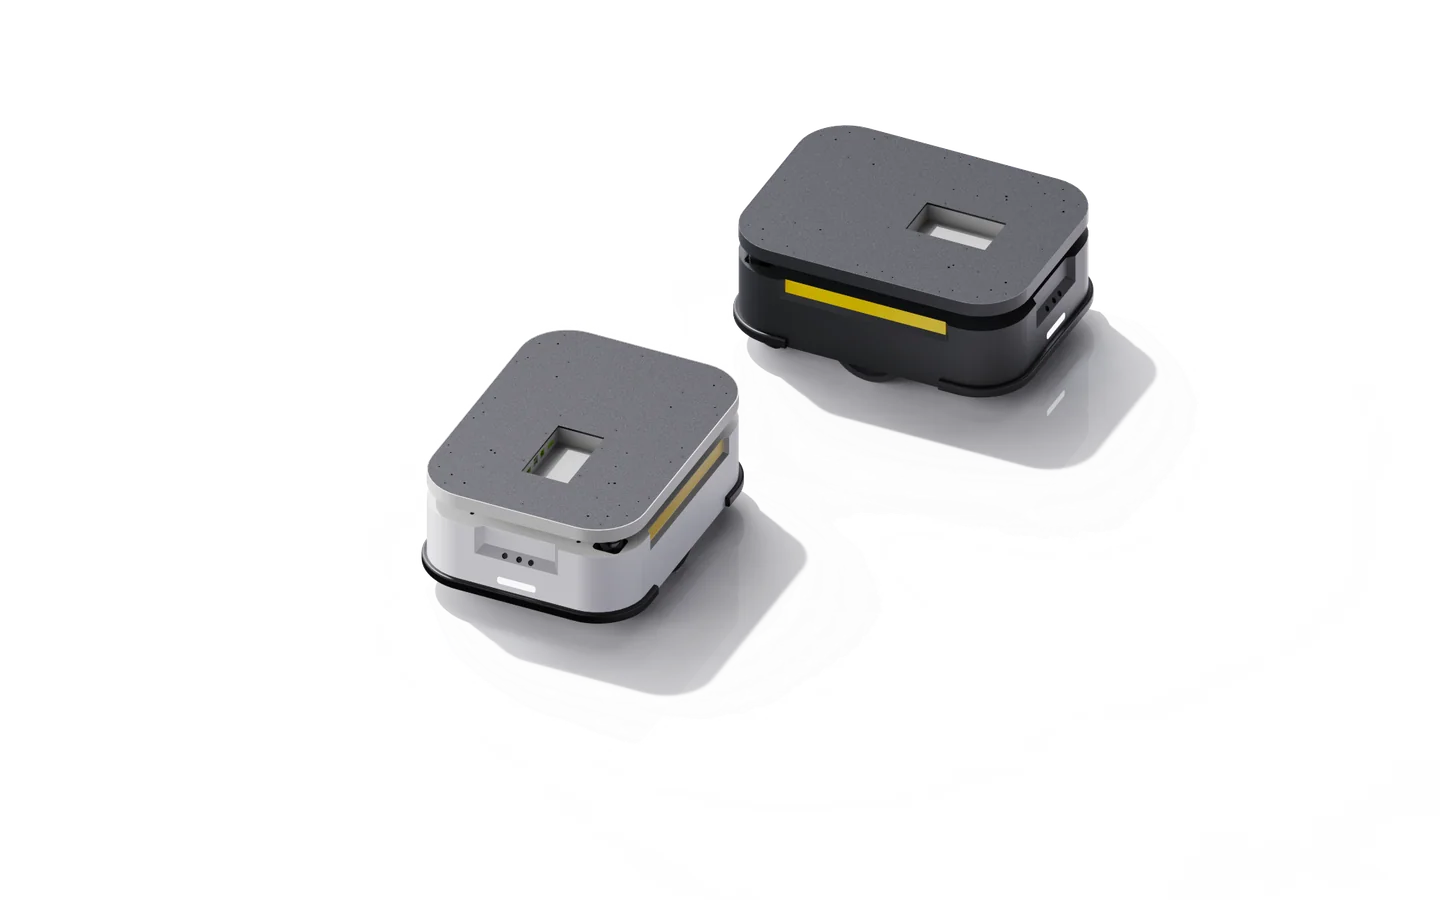
General-purpose differential-drive platform
600 × 450 × 260 mm
Payload 50 kg / 150 kg
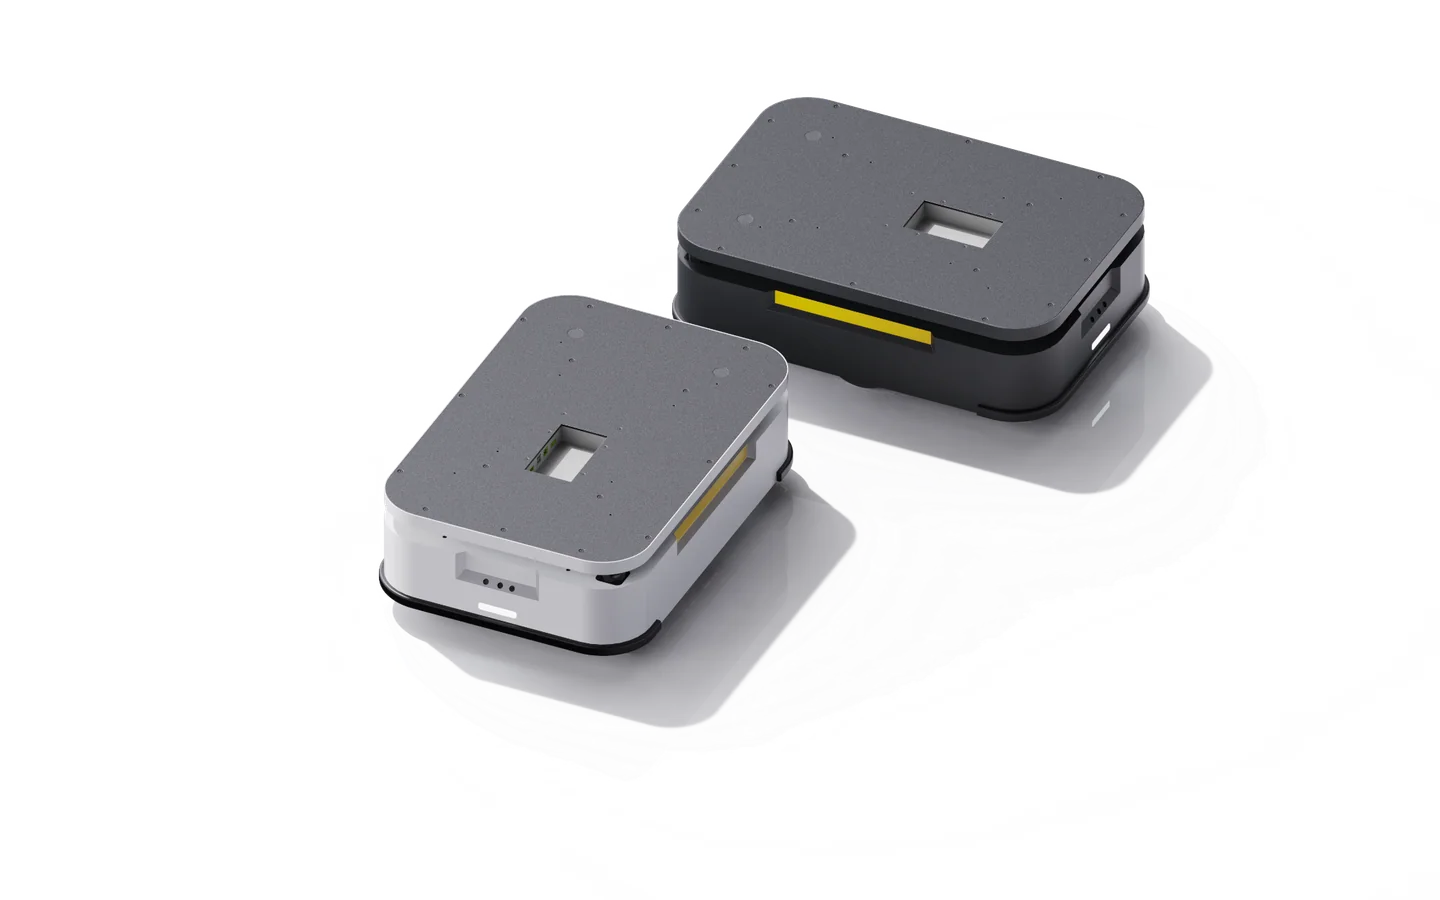
Expandable differential-drive platform
800 × 550 × 260 mm
Payload 150 kg
CUSTOM ROBOT DEVELOPMENT
Reuse standard chassis, shared hardware, unified interfaces and in-house algorithms to develop your product and upper modules, progressing from functional prototype to design finalization and mass production.
PLATFORM-BASED PROJECTS · TARGET TIMELINE
Reuse the chassis and controls, integrate upper modules and test core functions.
Complete scenario testing and design iterations; agree mechanical, hardware, software and acceptance requirements.
Complete pilot validation, sourcing, assembly and test preparation, then begin volume production.
These are cumulative target milestones from confirmed requirements and solution for projects that substantially reuse existing platforms. Agree the schedule against the project scope and solution.
DISCUSS YOUR PROJECT